


Shenzhen Jingcheng Dingyi Forming Technology Co., Ltd. is one of the leading manufacturers and suppliers of custom robotic hand housing for humanoid & dexterous robots in China, specialized in providing high quality customized products. If you're going to buy bulk cheap custom robotic hand housing for humanoid & dexterous robots, welcome to get quotation from our factory. Quality products and low price are available.
A robotic hand is more than a set of fingers and joints. The outer housing needs to protect internal mechanisms while maintaining the required hand shape, joint clearance and assembly interfaces.
Jingcheng provides customized manufacturing for robotic hand shells, finger covers, palm housings and wrist housings, helping robotics companies turn mechanical designs into production-ready components.
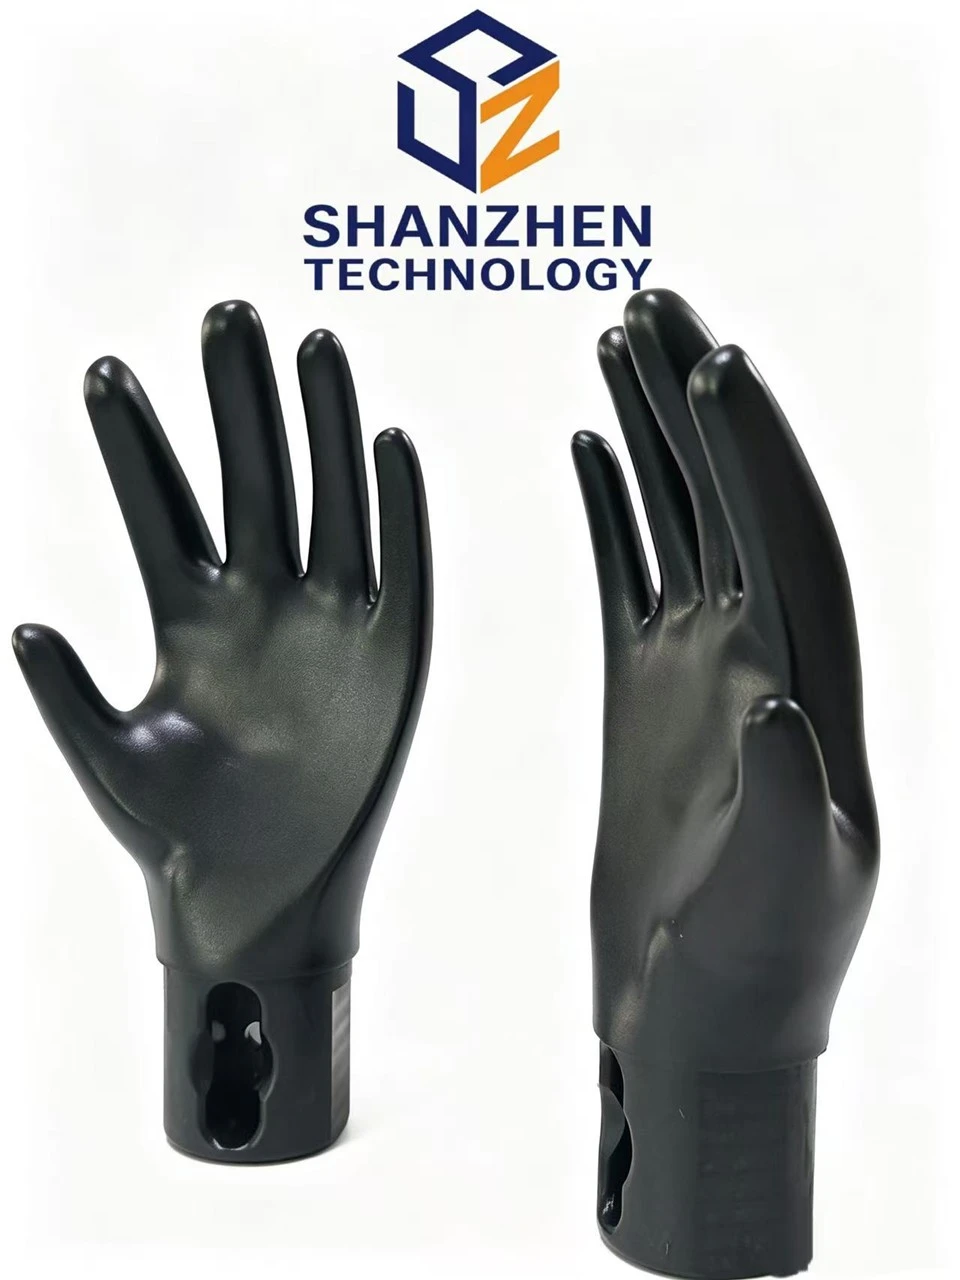
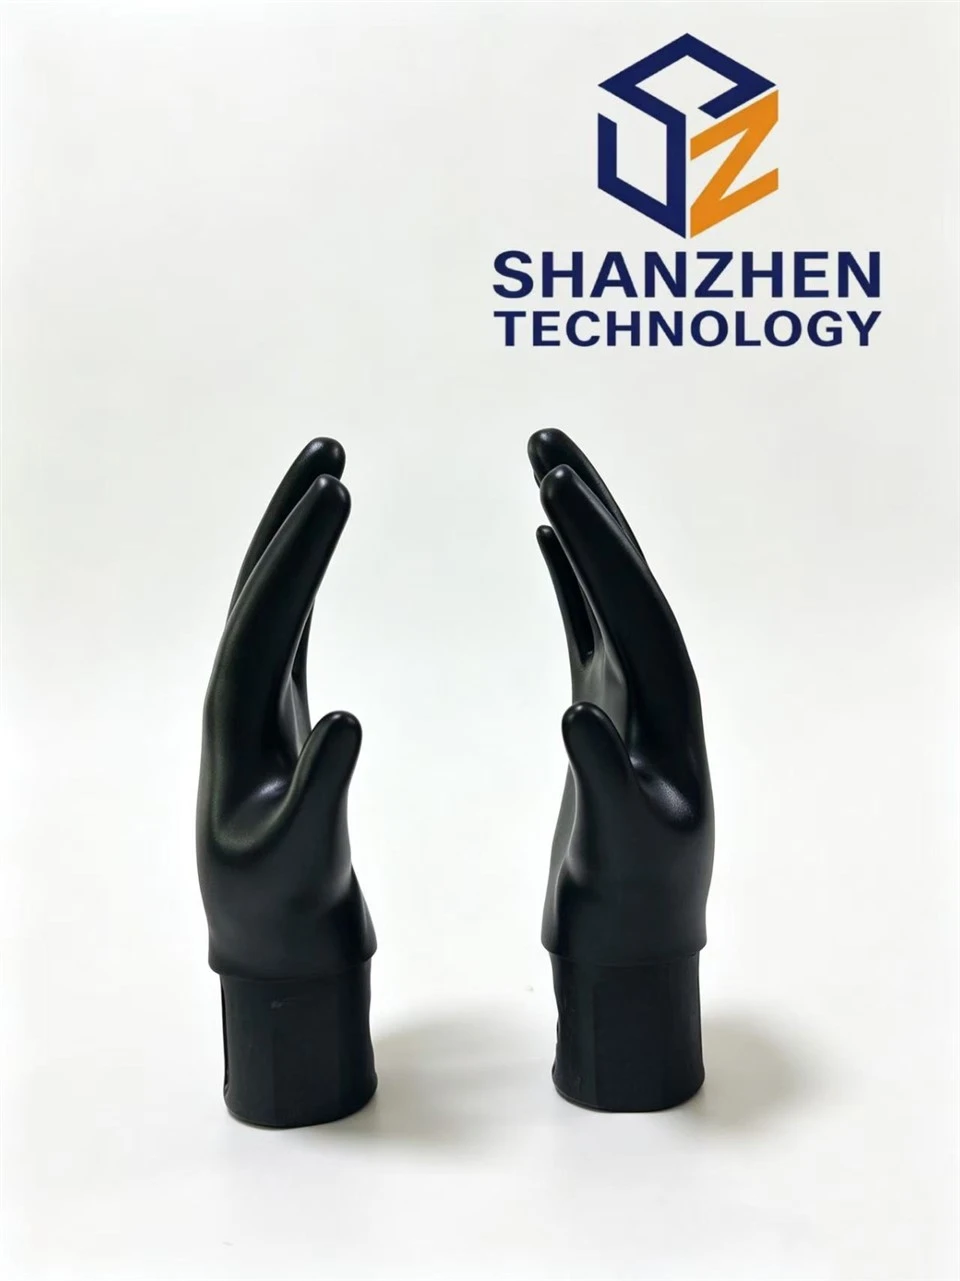
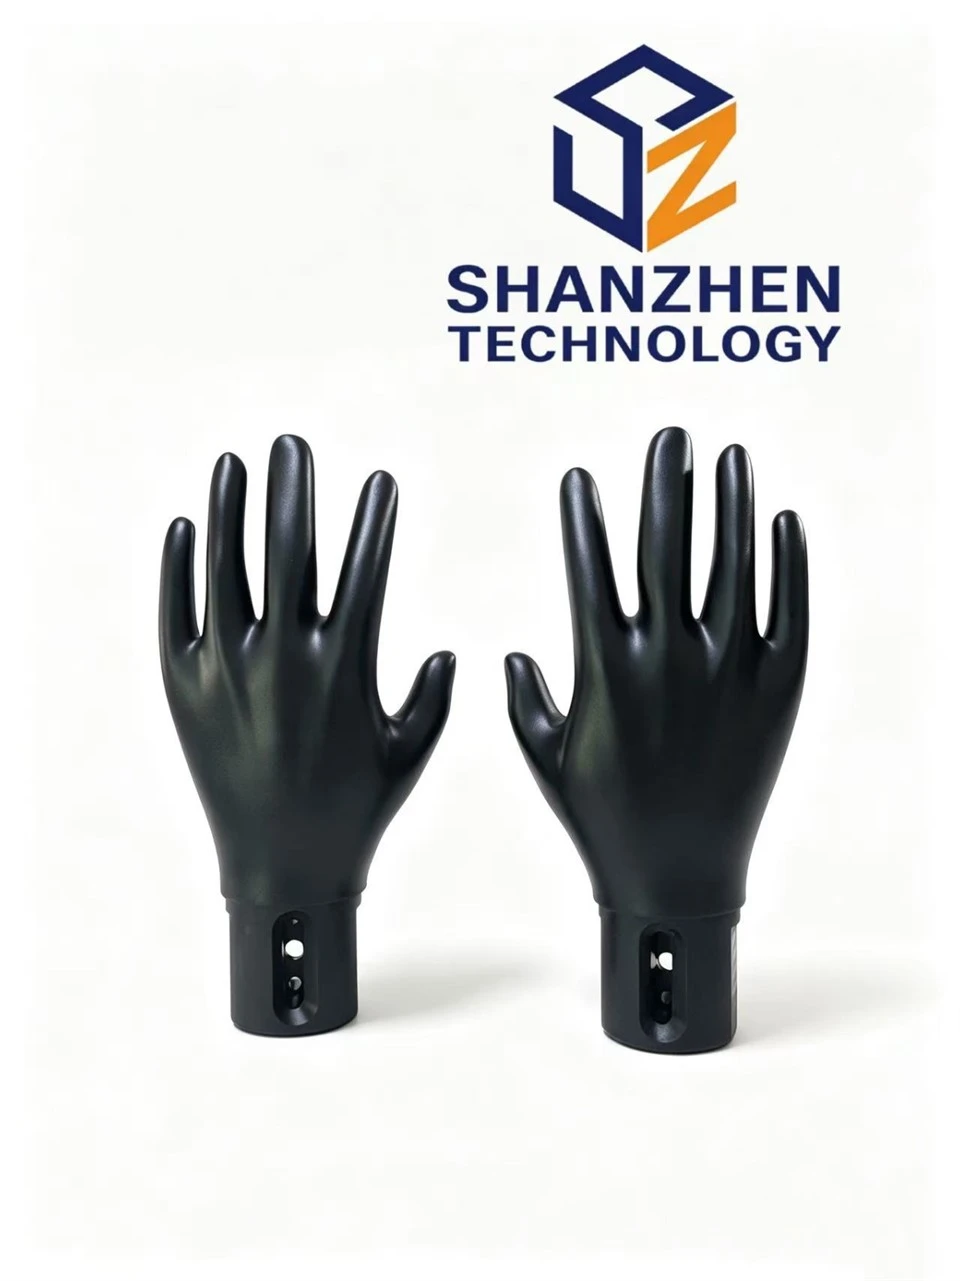
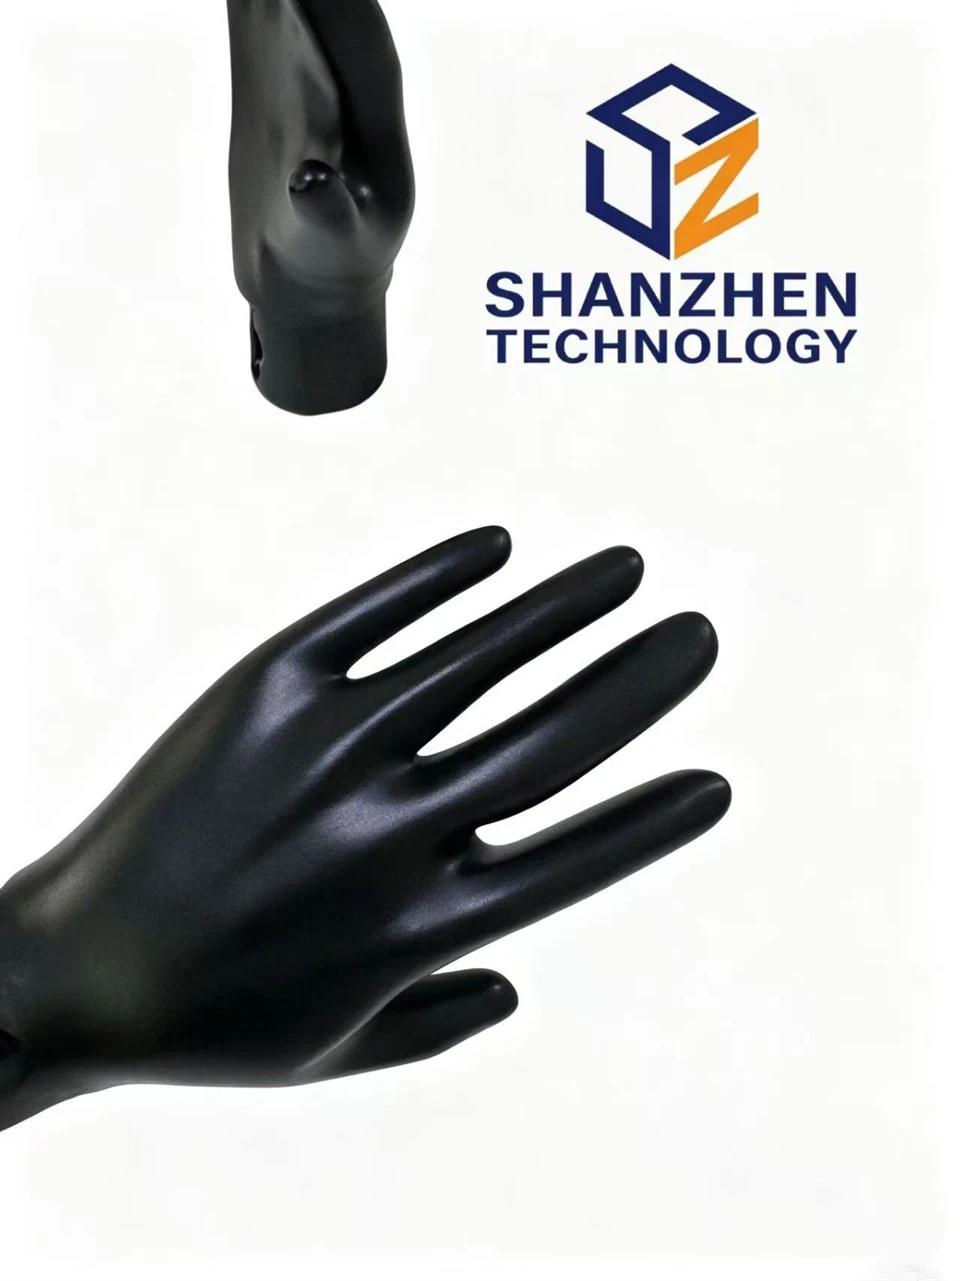
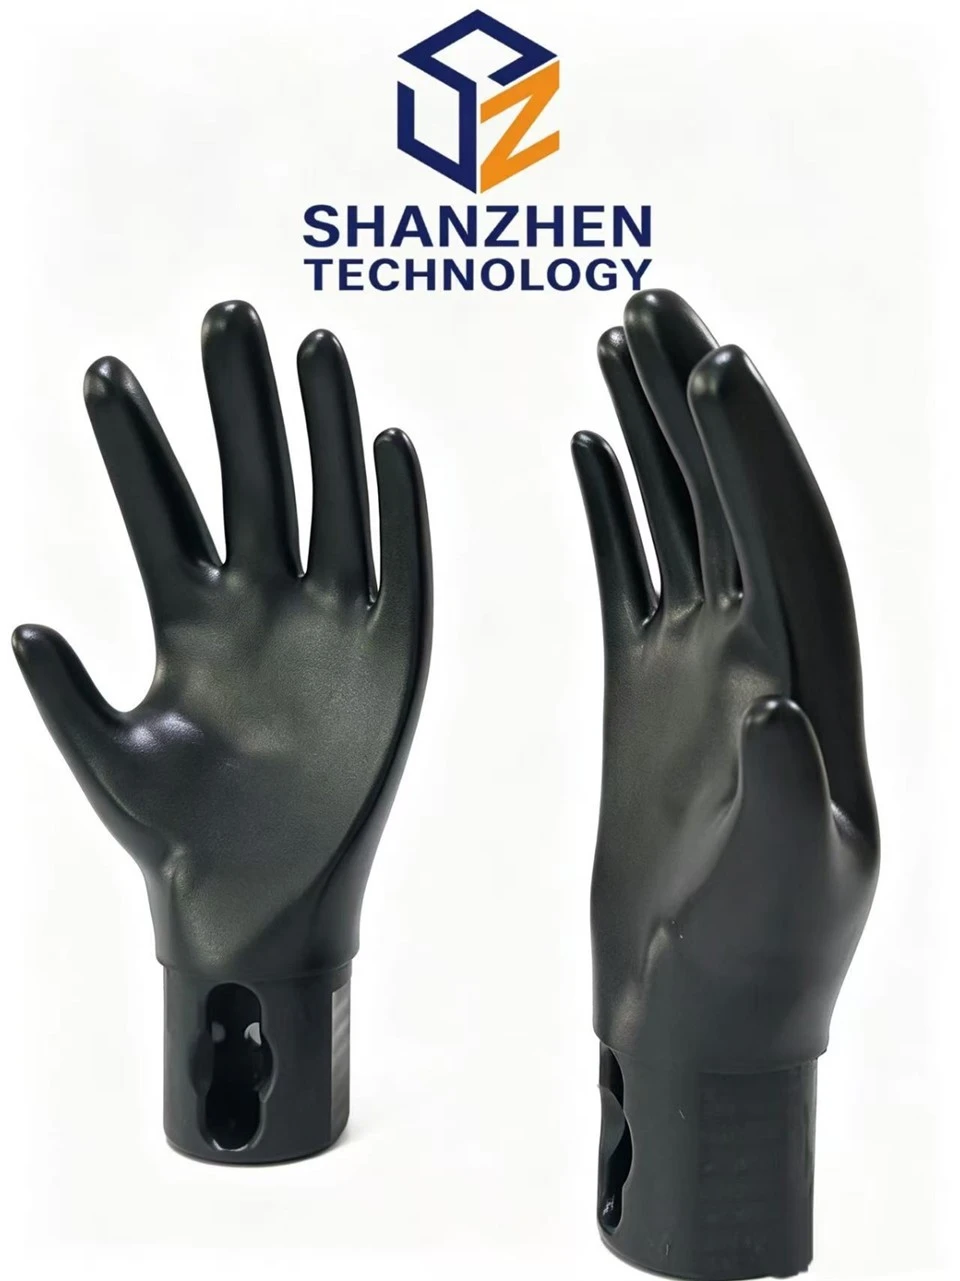
The black hand housing shown here is an example of the type of formed plastic robotic enclosure used around the mechanical structure of a robot hand.
Built Around the Internal Mechanism
The housing of a dexterous robotic hand usually has limited internal space. Motors, gear mechanisms, sensors, wiring and fasteners may all need to fit inside or around the hand structure.
For this reason, manufacturing starts from the customer's 3D CAD model and engineering drawings rather than from appearance alone.
During production preparation, we can review:
Finger and palm dimensions
Wall thickness and structural areas
Screw holes and mounting points
Joint clearance
Internal component space
Cable routing areas
Snap-fit or fastening structures
Interface between hand and wrist
Assembly access
This approach helps identify manufacturing problems before parts enter production.
Manufacturing for Different Development Stages
Robotics projects rarely start with hundreds or thousands of finished units. Engineers normally need several development stages, from an early physical prototype to functional samples and eventually small-batch production.
Jingcheng can support different manufacturing requirements according to the project stage.
- For prototypes, the priority is usually fast production and checking the physical fit of the housing.
- For functional prototypes, greater attention is given to mounting interfaces, assembly accuracy and interaction with internal mechanical components.
- For low-volume production, the focus shifts toward repeatability, surface consistency and stable dimensional control.
Depending on the material, geometry and required quantity, suitable manufacturing methods can be discussed based on the customer's design.
A Housing Is Only Useful When It Fits the Robot
For robotic hand components, dimensional accuracy is closely related to final assembly.
A small deviation around the wrist interface may affect installation. An incorrect opening around a finger joint may interfere with movement. Poorly positioned screw holes can also create problems when the housing is assembled with the internal mechanism.
Our production team therefore pays attention not only to individual dimensions but also to functional interfaces and assembly relationships.
For complex hand structures, multi-axis machining can also be considered for metal components or tooling-related parts where the design requires accurate 3D surfaces.
Typical Applications
Custom robotic hand housings can be developed for:
- Humanoid robot hands
- Dexterous robotic hands
- Bionic robotic hands
- Research robot platforms
- Service robots
- Educational robots
- Robotic grippers
- Teleoperation systems
- Human-robot interaction equipment
- Prototype robotic mechanisms
The housing can be developed as a complete palm shell, individual finger covers, wrist enclosure or a multi-piece protective structure.
From CAD File to Finished Component
If you already have a STEP, STP, IGES or other 3D CAD file, our engineers can review the design and manufacturing requirements before quotation.
For a new robotic hand project, it is useful to provide:
3D CAD model + 2D drawing + material requirement + quantity + surface finish + critical dimensions
If the design is still being developed, we can also discuss manufacturing considerations based on the available drawings and models.
Custom Robotic Hand Manufacturing
Whether you are developing a humanoid robot, dexterous hand or robotic gripper, the outer housing needs to match the mechanical architecture behind it.
Send us your robotic hand CAD file and requirements. Jingcheng can review the structure, manufacturing method, quantity and quality requirements before production.
Hot Tags: custom robotic hand housing for humanoid & dexterous robots, China custom robotic hand housing for humanoid & dexterous robots manufacturers


